No products in the cart.
Servo Motor Works in JOG Mode But Fails in CNC Operation: What’s the Cause?

Contents
A servo motor that functions correctly during JOG testing but exhibits errors in CNC operation often points to issues beyond basic motor function. This discrepancy typically arises from mismatches in PID parameters, encoder feedback problems, mechanical backlash, load variations during high-speed movements, communication delays, or a lack of synchronization between the CNC controller and the servo drive. A thorough analysis is required to identify the root cause.
Mermak CNC Technical Guide
Practical notes for CNC router, automation and industrial motion systems.
Understanding Servo Motor Behavior: JOG Test vs. CNC Operation
In industrial automation, particularly within CNC machinery, servo motors are indispensable for achieving precise positioning and speed control. It’s a common yet perplexing issue when a servo motor operates flawlessly in JOG (manual movement) mode but malfunctions under a full CNC program. This scenario usually indicates underlying problems not with the motor itself, but within the system’s dynamic response, control loop parameters, mechanical integration, or the communication interface between the CNC controller and the servo drive. The JOG test, typically performed at low speeds with simple commands, validates the basic functionality of the motor and drive. However, it doesn’t fully replicate the demands of high-speed, dynamic, and multi-axis coordinated movements characteristic of CNC operations. Consequently, a motor that passes JOG tests may falter when faced with the complex motion profiles, rapid acceleration/deceleration ramps, and continuous feedback requirements of CNC machining.
Operational Principles and Technical Data
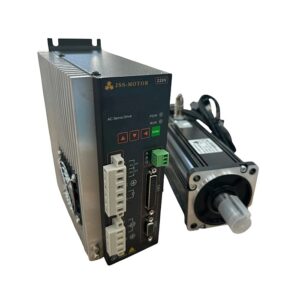
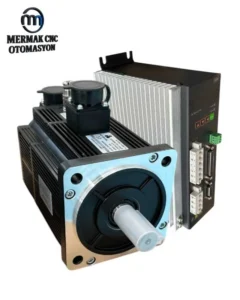
A servo motor system comprises a motor, a drive (amplifier), and a feedback device (encoder or resolver). The drive receives commands from the CNC controller, actuates the motor accordingly, and continuously monitors feedback data (actual position/speed) from the feedback device. This feedback loop enables the system to minimize the error signal—the difference between the commanded and actual values—to maintain the desired position or speed. This process, known as closed-loop control, is fundamental to achieving precision. In CNC applications, this closed-loop control operates under much higher demands for dynamism and accuracy.
During JOG mode, operators typically move the motor at slow speeds and on a single axis. The system’s dynamic response, acceleration/deceleration times, and positioning accuracy requirements are minimal. PID gains can often suffice with standard or more ‘lenient’ settings. However, CNC mode presents a completely different challenge. Through G-code instructions, CNC machines execute complex interpolations, simultaneous multi-axis movements, sharp directional changes at high speeds, and aggressive acceleration/deceleration profiles. These conditions necessitate precise tuning of the servo system’s PID gains, as well as its speed loop, current loop, and position loop. Improperly tuned PID gains can lead to the motor struggling to reach its target (high following error), oscillating around the target (overshoot/hunting), or responding sluggishly.
Furthermore, the mechanical loads encountered during CNC operations can differ significantly from those in JOG mode. A motor operating unloaded or under low load during JOG might be insufficient when the CNC program demands high cutting forces, handling heavy workpieces, or rapid tool changes. This can cause the motor or drive to reach its torque limits, draw excessive current, or overheat. Encoder feedback is vital for CNC accuracy. Electrical noise generated during high-speed movements can corrupt encoder signals, leading to inaccurate position data. This, in turn, causes the control loop to make incorrect corrections, resulting in faulty positioning.
| Parameter | Value/Description |
|---|---|
| PID Gain Settings | Proportional (Kp), Integral (Ki), Derivative (Kd) values. Must be optimized for dynamic load and required precision in CNC. |
| Encoder Resolution | Pulses per revolution. Must be sufficient for CNC precision (e.g., over 2500 PPR, incremental or absolute). |
| Acceleration/Deceleration Ramps | Time taken for the motor to reach maximum speed and stop. More aggressive and dynamic values are used in CNC. |
| Communication Cycle Time | Data exchange time between CNC controller and drive (e.g., <1ms for EtherCAT). Latency can cause errors. |
| Maximum Following Error | Maximum allowable difference between commanded and actual position. This limit is much tighter in CNC. |
| Mechanical Backlash | Play in ball screws, linear guides, or couplings. Causes positioning errors during direction changes in CNC. |
| Drive Current Capacity | Maximum current the drive can supply to the motor. Must be sufficient for high torque demands in CNC. |
Key Considerations for Field Troubleshooting
- PID Parameter Optimization: A servo operating in JOG mode might use default or minimally adjusted PID parameters. However, CNC operations, especially those requiring high speed and precision, demand accurate and meticulous tuning of PID gains. Insufficient Kp (Proportional gain) can lead to high following errors, while excessive Kp may cause oscillations. Ki (Integral gain) reduces steady-state error, and Kd (Derivative gain) improves system response and prevents overshoot. These settings must consider the machine’s mechanical resonance frequencies and load inertia. While auto-tuning functions can be a starting point, final optimization often requires manual fine-tuning.
- Mechanical System Inspection: Slow movements in JOG mode can mask issues like mechanical backlash, friction, or misalignment. However, rapid directional changes, high accelerations, and loads in CNC operations will expose these problems. Wear or looseness in ball screws, linear guide rails, gearboxes, and couplings can cause positioning errors, particularly during direction reversals. Checking for backlash by manually rotating the axis or using a dial indicator, and verifying the smooth operation of guides and bearings, is crucial. Even minor play or looseness in mechanical components can significantly impact CNC precision.
- Encoder Feedback and Cabling Integrity: The encoder, which provides position and speed information to the servo motor, is a critical component for CNC accuracy. Electrical noise, breaks, loose connections, or inadequate shielding in encoder cables can generate erroneous feedback signals, especially during high-speed movements. This leads the servo drive to make incorrect corrections, resulting in positioning errors. Verifying encoder signals with an oscilloscope and inspecting cable grounding and connection tightness is essential. Ensure the encoder is mechanically secured to the motor or load; a loose encoder will transmit inaccurate data.
- CNC Controller and Communication Protocols: The communication between the servo drive and the CNC controller, particularly when using real-time protocols like EtherCAT or PROFINET IRT, is paramount. Latency or communication errors can prevent commands from reaching the motor promptly and accurately. Ensure the controller software is up-to-date, communication cables (Ethernet, fiber optic, etc.) are intact, and connectors are properly seated. Axis settings, pulse/revolution ratios, and other parameters within the controller must precisely match their counterparts in the drive.
By systematically investigating these areas—PID tuning, mechanical integrity, encoder feedback, and controller communication—you can effectively diagnose and resolve issues where a servo motor performs well in JOG mode but fails during CNC operation. This ensures reliable and precise performance from your industrial CNC router machine.
For expert assistance with your servo motor systems and CNC machinery, don’t hesitate to reach out. Request a quote on WhatsApp today!
Related product categories: Genel · Mekanik · AC Servo Motor